Explainable AI · Robotics

Hi, I'm Tien Pham.

Marie Skłodowska-Curie Early Career Researcher and PhD student at The University of Manchester, UK.

I build transparent, interpretable and generalizable learning systems for autonomous robots — so that people can understand, trust and safely work alongside them.
  • Explainable AI
  • Vision-Language Models
  • Cognitive Robotics
  • Reinforcement Learning
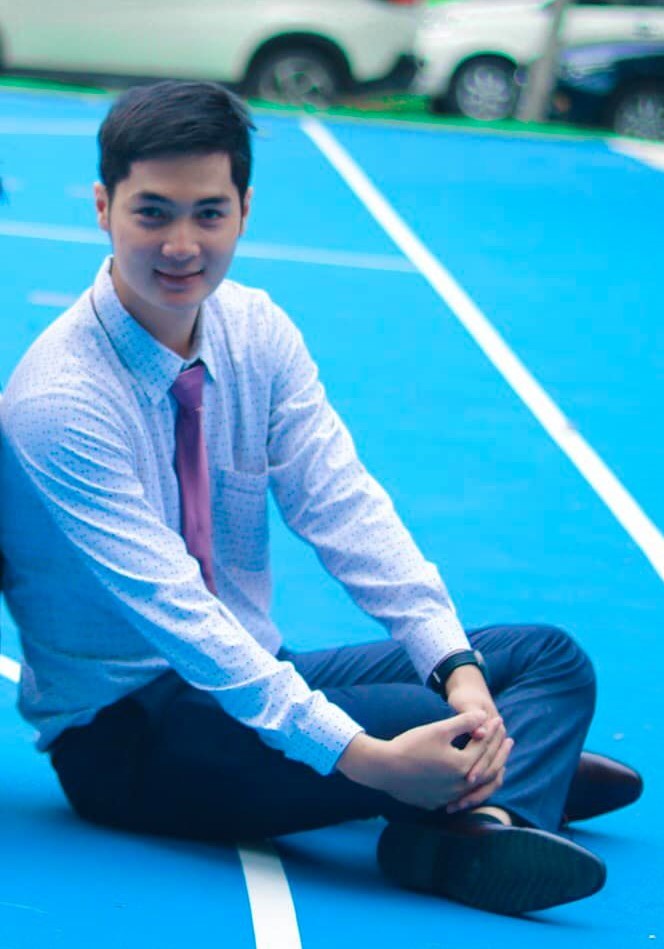
Portrait of Tien Pham
PhD, Computer ScienceUniv. of Manchester · 2023–2026
About

Making robots that can explain themselves

My research focuses on Explainable Artificial Intelligence, Vision-Language Models and Cognitive Robotics. I develop transparent, interpretable and generalizable learning systems for autonomous robots, addressing fundamental challenges in trust, safety and human–AI interaction.

Within the Marie Curie Doctoral Network I have completed an academic secondment at LAAS-CNRS (Toulouse, France) and an industrial secondment at PAL Robotics (Barcelona, Spain). I also organize the TRAIL conference and review for IJCNN, IROS, ICDL and RO-MAN.

Before Manchester, I earned an M.Sc. in Computer Science from The University of Texas at Arlington, USA, worked as an embedded software developer at Bosch, and earned a B.E. in Mechatronics from Ho Chi Minh City University of Technology (Bach Khoa), Vietnam.

12Peer-reviewed papers
2Patents
4Conferences reviewed for
4.00M.Sc. GPA (UTA)
Journey

Education & experience

From mechatronics in Vietnam to explainable robotics in the UK.

  1. Ph.D.2023 – 2026 · Manchester, UK

    Ph.D., Computer Science

    The University of Manchester · Marie Curie Early Career Researcher
    Thesis
    Interactive Language Explanation and Visualization for Explainable Robotics
    Supervisor
    Prof. Angelo Cangelosi
    Focus
    Explainable deep RL, VLMs, robotics
    Secondments
    LAAS-CNRS (Toulouse, FR) · PAL Robotics (Barcelona, ES)
  2. M.Sc.2021 – 2023 · Texas, USA

    M.Sc., Computer Science — GPA 4.00 / 4.00

    The University of Texas at Arlington
    Thesis
    Context-aware interface for a semi-autonomous smart wheelchair
    Supervisor
    Prof. Manfred Huber
    Courses
    Machine Learning, Data Mining, Cloud Computing, Distributed Systems, Algorithms, Computer Architecture
  3. Industry2019 – 2021 · Vietnam

    Embedded Software Developer

    Bosch
    Focus
    Automotive embedded software (AUTOSAR)
  4. B.E.2014 – 2019 · Ho Chi Minh City, VN

    B.E., Mechatronics — GPA 8.21 / 10

    Ho Chi Minh City University of Technology (Bach Khoa) · PFIEV programme
    Thesis
    Design of an undulating fin for autonomous underwater vehicles (highest score: 9.54 / 10)
    Supervisor
    Dr. Tan-Tien Nguyen
At a glance — click to enlarge
Research

Selected projects

Interpretable learning for robots, plus earlier work on wearable and battery-free sensing.

Under review

Completeness-Aware Task Planning and Execution using Pretrained Vision-Language Models in Manipulation Control

  • VLMs
  • Task & motion planning
  • ROS 2
  • Manipulation
CASE 2026

CGGT: Concept-Guided Grounded Training for Generalizable and Interpretable Reinforcement Learning in Robot Control

  • Concept bottleneck models
  • Interpretable RL
  • Generalization
UR 2026

DeGuV: Depth-Guided Visual Reinforcement Learning for Generalization and Interpretability in Manipulation

  • Visual RL
  • Depth guidance
  • Interpretability
IJCNN 2025

Pay Attention to What and Where? Interpretable Feature Extractor in Vision-based Deep Reinforcement Learning

  • Attention
  • Deep RL
  • Explainable AI
M.Sc. thesis

Context-Aware Interface for a Semi-Autonomous Smart Wheelchair

  • ROS Noetic
  • YOLO
  • Gaze estimation
  • Head pose estimation
AES 2022 · Abstract

Real-Time Seizure Detection Using a Behind-The-Ear Wearable System

  • Brain signals
  • Wearable devices
ACM MobiCom 2022

IoTree: A Battery-free Wearable System with Biocompatible Sensors for Continuous Tree Health Monitoring

  • IoT
  • Battery-free
  • Sensing
ACM MobiCom 2021

BioFace-3D: Continuous 3D Facial Reconstruction Through Lightweight Single-Ear Biosensors

  • Muscle signals
  • Virtual reality
ACM UbiComp / IMWUT 2021

FaceSense: Sensing Face Touch with an Ear-worn System

  • Multi-modal sensing
  • Wearables
Publications

Papers & patents

Conference & journal papers

  1. 2026
    DeGuV: Depth-Guided Visual Reinforcement Learning for Generalization and Interpretability in Manipulation
    Tien Pham, Xinyun Chi, Khang Nguyen, Manfred Huber, Angelo Cangelosi

    2026 23rd International Conference on Ubiquitous Robots, IEEE, pp. 1–7

    UR 2026 IEEE arXiv Code
  2. 2026
    INPERAL: Interactive Perception Alignment in Human-Robot Interaction
    Canh An Tien Pham, Xinyun Chi, Angelo Cangelosi

    2026 IEEE International Conference on Robot and Human Interactive Communication

    RO-MAN 2026 Manchester Research
  3. 2026
    CGGT: Concept-Guided Grounded Training for Generalizable and Interpretable Reinforcement Learning in Robot Control
    Tien Pham, Khang Nguyen, Angelo Cangelosi

    2026 IEEE 22nd International Conference on Automation Science and Engineering

    CASE 2026 IEEE PDF
  4. 2025
    FlowMP: Learning Motion Fields for Robot Planning with Conditional Flow Matching
    Khang Nguyen, An T. Le, Tien Pham, Manfred Huber, Jan Peters, Minh Nhat Vu

    IEEE/RSJ International Conference on Intelligent Robots and Systems

    IROS 2025
  5. 2025
    Pay Attention to What and Where? Interpretable Feature Extractor in Vision-based Deep Reinforcement Learning
    Tien Pham, Angelo Cangelosi

    The 38th International Joint Conference on Neural Networks

    IJCNN 2025 arXiv Code
  6. 2022
    IoTree: A Battery-free Wearable System with Biocompatible Sensors for Continuous Tree Health Monitoring
    Tuan Dang, Trung Tran, Khang Nguyen, Tien Pham, Nhat Pham, Tam Vu, Phuc Nguyen

    Proceedings of the 28th Annual International Conference on Mobile Computing and Networking

    MobiCom 2022
  7. 2021
    FaceSense: Sensing Face Touch with an Ear-worn System
    Vimal Kakaraparthi, Qijia Shao, Charles Carver, Tien Pham, Nam Bui, Phuc Nguyen, Xia Zhou, Tam Vu

    Proceedings of the ACM on Interactive, Mobile, Wearable and Ubiquitous Technologies, pp. 1–27

    IMWUT 2021 PDF
  8. 2021
    BioFace-3D: Continuous 3D Facial Reconstruction through Lightweight Single-Ear Biosensors
    Yi Wu, Vimal Kakaraparthi, Zhang Li, Tien Pham, Jian Liu, Phuc Nguyen

    Proceedings of the 27th Annual International Conference on Mobile Computing and Networking, pp. 350–363

    MobiCom 2021 PDF
  9. 2019
    Study on Velocity Control of Gymnotiform Undulating Fin Module
    Van Hien Nguyen, Canh An Tien Pham, Van Dong Nguyen, Tan Tien Nguyen

    International Conference on Advanced Engineering Theory and Applications, Springer, Cham, pp. 714–725

    AETA 2019
  10. 2018
    Computational Study on Upward Force Generation of Gymnotiform Undulating Fin
    Van Hien Nguyen, Canh An Tien Pham, Van Dong Nguyen, Hoang Long Phan, Tan Tien Nguyen

    International Conference on Advanced Engineering Theory and Applications, Springer, Cham, pp. 914–923

    AETA 2018
  11. 2018
    Modular Design of Gymnotiform Undulating Fin
    Van Dong Nguyen, Canh An Tien Pham, Van Hien Nguyen, Thien Phuc Tran, Tan Tien Nguyen

    International Conference on Advanced Engineering Theory and Applications, Springer, Cham, pp. 924–931

    AETA 2018
  12. 2018
    A Study on Force Generated by Gymnotiform Undulating Fin
    Van Hien Nguyen, Canh An Tien Pham, Van Dong Nguyen, Dae Hwan Kim, Tan Tien Nguyen

    The 15th International Conference on Ubiquitous Robots, IEEE, pp. 241–246

    UR 2018

Patents

  1. 2022
    Method and Apparatus for Continuous Plant Health Monitoring Using a Battery-free System with Biocompatible Implanted Sensors
    Patent · accepted
  2. 2021
    Method and Apparatus for Continuous 3D Facial Reconstruction Through Lightweight Single-ear Biosensors
    Patent

No publications match your search.

Community

Service & activities

Conference organizer

Organizer of the TRAIL conference on trustworthy robotics and AI.

Reviewer

  • IJCNN — Int. Joint Conf. on Neural Networks
  • IROS — IEEE/RSJ Int. Conf. on Intelligent Robots and Systems
  • ICDL — IEEE Int. Conf. on Development and Learning
  • RO-MAN — IEEE Int. Conf. on Robot and Human Interactive Communication

Secondments

  • LAAS-CNRS, Toulouse, France — academic
  • PAL Robotics, Barcelona, Spain — industrial
Blog

Notes & tutorials

Beyond research

Conferences, travel & basketball